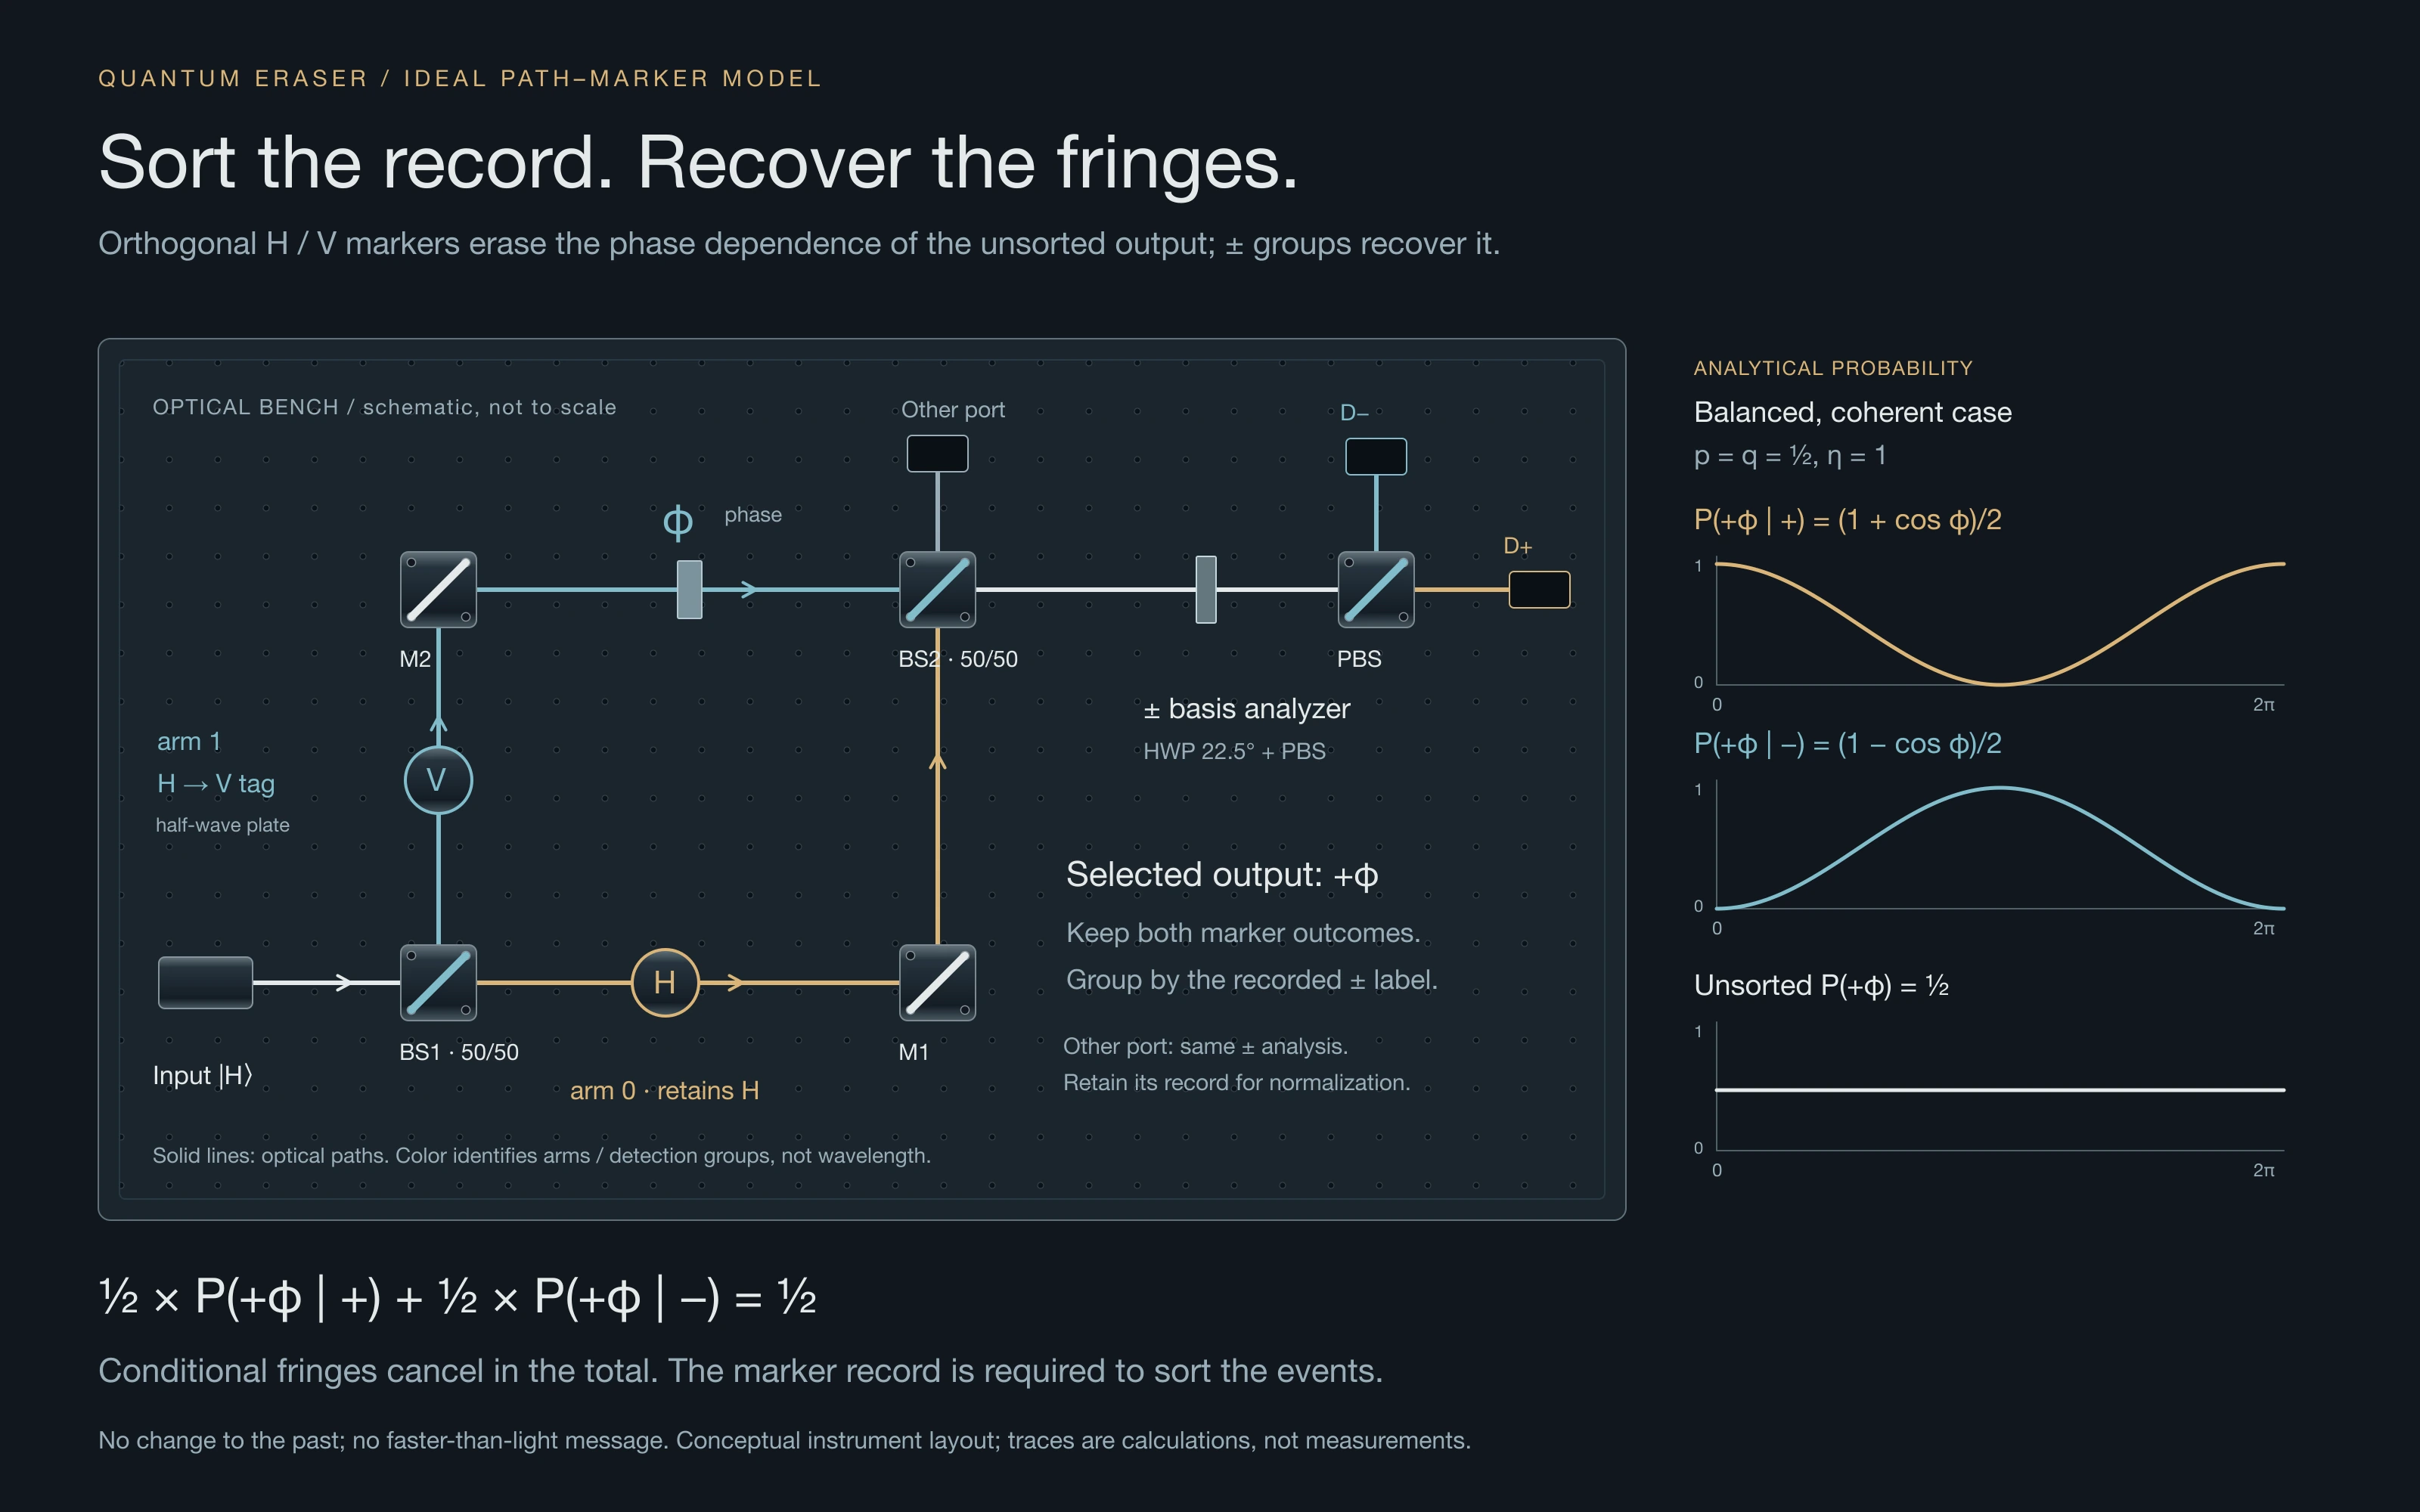
Quantum Eraser: From Which-Path Information to Conditional Fringes
The research question and the complete development
How much interference can coexist with information about the path a quantum system took? What changes when the paths are unequal, when phase coherence is lost, or when results are selected after a marker measurement? And why can a selected group show interference while the unselected detection statistics do not change?
This research began with a comparison between double-slit physics and the higher-dimensional storytelling of Interstellar. It developed into explicit quantum-state calculations, checks of physically allowed channels, and two different seventh-round investigations of conditional statistics. The useful result is a chain of models and counterexamples: numerical values are connected to states and measurements, rather than presented as unexplained scores.
The account below preserves that progression, including proposals that failed, assumptions that changed, and questions that remain open. Rounds 1–6 lead to two preserved Round 7 branches. One studies complementary eraser outcomes; the other studies an apparent violation manufactured by combining different selected ensembles. They have a common Round 6 parent, but they are different calculations and their test counts must not be combined.
All reported tests here are mathematical or numerical checks of stated models. They are not counts of photons, laboratory trials, or independent experiments. Explanatory algebra has been expanded to make the archived calculations readable; the eraser branch's missing detailed probability artifact is identified explicitly in its chapter.
Definitions: what is being calculated?
A two-path system has orthogonal path states |0⟩ and |1⟩. A separate marker becomes correlated with the path. The marker states need not be orthogonal: if they overlap, they cannot be perfectly distinguished in a single measurement.
Let p be the probability of path 0, let q = 1 − p, and let the normalized marker states be |m₀⟩ and |m₁⟩. Define their overlap γ = ⟨m₀|m₁⟩. The earlier numerical examples choose γ real and nonnegative. A coherent joint state is
|Ψ⟩ = √p |0⟩|m₀⟩ + √q |1⟩|m₁⟩.
The orthogonality of the path states makes this state normalized when p + q = 1. The joint Hilbert space has dimension four when the marker is also two-dimensional. Four-dimensional state space here means two qubits' joint mathematical state space; it does not mean four spatial dimensions.
Visibility V
Visibility measures fringe contrast:
V = (Pmax − Pmin)/(Pmax + Pmin).
For the ideal balanced output measurement used in these models, the path density matrix ρP produces a phase-dependent probability
P(+φ) = 1/2 + Re(e^{iφ} ρP,01).
Changing a phase convention changes the sign of φ, not the visibility. Since the diagonal populations sum to one,
V = 2|ρP,01|.
A plotted φ is an interferometric phase. It is not automatically a position on a physical detection screen. A screen model would additionally need propagation amplitudes, geometry, the detector envelope, and a relation between phase and position.
Distinguishability D
The earlier rounds use optimal binary discrimination of the available marker states, including the path priors:
D = ‖p|m₀⟩⟨m₀| − q|m₁⟩⟨m₁|‖₁.
The trace norm of a Hermitian matrix is the sum of the absolute values of its eigenvalues. The corresponding optimal path-guessing probability is (1 + D)/2. For the pure markers used here,
D = √(1 − 4pq|γ|²).
For equal priors this becomes √(1 − |γ|²). The prior-only predictability is instead |p − q|. These quantities agree in some limiting cases but cannot be substituted for one another in general.
D always depends on what information is available. Knowledge accessible in the specified marker is not identical to knowledge available to an observer who can also access an additional environment.
The channel parameter η
A path-only pure-dephasing channel multiplies the off-diagonal path blocks by η without changing path populations or the conditional marker states. For the examples here 0 ≤ η ≤ 1. Consequently,
V = 2√pq |γ|η,
D² + V² = 1 − 4pq|γ|²(1 − η²).
This is the common mathematical framework underlying Rounds 2–6. It explains both equality before dephasing and a strict inequality after dephasing. It is not a claim that every kind of noise preserves D.
Round 1: the analogy is narrowed before the model is built
Starting question
Could arbitrarily clear interference coexist with arbitrarily reliable information about which slit was used? Could the word “observer” in this setting be identified with the film's higher-dimensional viewpoint?
Calculation actually recorded
The first substantive all-topic record applied D² + V² ≤ 1 to two assumed pairs:
- D = 0.6, V = 0.8 gives 0.36 + 0.64 = 1.00.
- D = 0.6, V = 0.9 gives 0.36 + 0.81 = 1.17.
The first pair satisfies the inequality; the second does not, within its stated two-path operational definitions. These were assumed numbers, not values derived from a prepared state. Passing the scalar inequality alone did not establish a complete physical implementation.
Attack and rejected proposal
The attempted bridge to the film confused three different meanings of dimension and information:
- the dimension of quantum state space;
- coordinates of physical spacetime;
- a viewer's or character's access to a narrative.
The inequality supplies no physical mapping from one to another. The initial direct inference from a cinematic higher-dimensional view to quantum measurement was therefore rejected. Acquiring which-path information involves physical correlations; a conscious viewer is not required by this model.
What changed and what came next
The line retained a precise physics question while dropping the unsupported physical analogy. The next necessary repair was to construct marker states that actually produced a chosen pair of D and V, rather than merely selecting numbers that fit an inequality.
Round 2: a normalized state replaces arbitrary numbers
Question inherited from Round 1
Can a realizable pure path-marker state produce a specific visibility and distinguishability?
State construction
The marker states were chosen as
|m₀⟩ = |0⟩,
|m₁⟩ = (3/5)|0⟩ + (4/5)|1⟩.
Both have unit norm and their overlap is 3/5. With equal path weights, the joint state is
|Ψ⟩ = (|0⟩|m₀⟩ + |1⟩|m₁⟩)/√2.
Tracing out the marker gives the path matrix
ρP = [[1/2, 3/10], [3/10, 1/2]].
Thus V = 2(3/10) = 3/5. Optimal discrimination of the two pure marker states gives D = √(1 − 9/25) = 4/5, so D² + V² = 1 exactly. The stored result retains the rational values 3/5 and 4/5 rather than only rounded decimals; the implementation checks the identity symbolically.
Attack and interpretation
This derivation depends on pure markers, equal path priors, and access to the marker used in the discrimination definition. It does not settle mixed markers or unequal priors.
The round also distinguished conditional sorting from changing the unsorted past: a marker measurement can define subgroups with different interference behavior, but combining all outcomes recovers the original unconditioned detection statistics. This was an interpretive boundary in Round 2, not yet the later full eraser grid calculation.
Next question
Introduce noise and unequal paths in ways that preserve a valid quantum state. Identify when the equality becomes a strict inequality.
Round 3: phase noise reduces contrast without improving the marker
Question
Does every reduction in interference imply that the specified marker contains more which-path information?
Model change and result
Round 3 retained γ = 0.6 and equal path probabilities but introduced an independent phase-dephasing factor η = 0.5. The marker states were left unchanged. The calculation was
D = √(1 − 0.6²) = 0.8,
V = 0.5 × 0.6 = 0.3,
D² + V² = 0.64 + 0.09 = 0.73.
The archive records two passing checks: D = 0.8 together with V = 0.3, and the expected sum 0.73. This demonstrates a strict inequality in the specified model.
Attack and repair required
The proposed generalization “lower contrast means more readable path information” fails: this channel lowers coherence without changing the two available marker states. The converse overgeneralization also fails: not all noise acts only on phase. Noise that alters populations, the marker states, or available environmental information requires a different calculation.
At this stage η was inserted through the model's formula. The next unresolved task was to exhibit a positive density matrix for unequal paths, followed by an explicit joint channel.
Round 4: unequal paths and a positive reduced state
Question
Can the dephased example be represented by a physical density matrix when one path is four times as probable as the other?
Inputs and calculation
The inputs changed to p = 0.8, q = 0.2, γ = 0.6, η = 0.5. The off-diagonal element is
√pq γη = √0.16 × 0.6 × 0.5 = 0.12.
The reduced state is
ρP = [[0.8, 0.12], [0.12, 0.2]].
It is Hermitian, has trace one, and has eigenvalues approximately 0.1768901116 and 0.8231098884. Both are nonnegative. Its visibility is 0.24.
The marker-assisted distinguishability, with these priors, is
D = √(1 − 4 × 0.8 × 0.2 × 0.6²) = √0.7696 ≈ 0.877268488.
The resulting sum is 0.7696 + 0.0576 = 0.8272.
Four recorded checks
- Hermiticity and unit trace.
- Positive semidefiniteness.
- Visibility equal to 0.24.
- Satisfaction of the duality bound.
Attack: prior bias is not marker-assisted distinguishability
The prior-only bias is |0.8 − 0.2| = 0.6. It is not D ≈ 0.8773. Simply guessing the more likely path and optimally measuring a path-correlated marker are different procedures.
A positive reduced path state alone also does not display the complete joint-state and channel construction that links the chosen marker states to D. Round 4 therefore set the next task explicitly: construct the four-dimensional joint density matrix and Kraus operators, and obtain D and V by different numerical routes.
Round 5: the full joint state and an explicit allowed channel
Question
Can a trace-preserving quantum channel reproduce Round 4's marginal numbers from the complete path-marker state?
Joint state
Using the basis |00⟩, |01⟩, |10⟩, |11⟩, with the path label first, the initial vector is
|Ψ⟩ = (√0.8, 0, 0.6√0.2, 0.8√0.2)ᵀ ≈ (0.8944271910, 0, 0.2683281573, 0.3577708764)ᵀ.
The initial density matrix is |Ψ⟩⟨Ψ|. Set ZP = diag(1, −1) on the path and I on the marker. The two channel operators are
K₀ = √((1 + η)/2) I₄,
K₁ = √((1 − η)/2) (ZP ⊗ I₂).
They satisfy K₀†K₀ + K₁†K₁ = I₄. For η = 0.5 the multipliers are √0.75 and √0.25. The output is ρ′ = K₀ρK₀† + K₁ρK₁†.
To the precision displayed in the archived output,
ρ′ = [[0.800, 0, 0.120, 0.160], [0, 0, 0, 0 ], [0.120, 0, 0.072, 0.096], [0.160, 0, 0.096, 0.128]].
The channel changes cross-path coherence while retaining the within-path marker blocks.
Two computational routes
For visibility, the code traces over the marker by summing matching marker indices in the joint density matrix. The result is the same reduced state as Round 4, with off-diagonal 0.12 and V = 0.24.
For distinguishability, it constructs the weighted marker difference
Δ = p|m₀⟩⟨m₀| − q|m₁⟩⟨m₁| = [[0.728, −0.096], [−0.096, −0.128]].
Summing the absolute eigenvalues gives D = 0.8772684879784525. The closed-form calculation gives 0.8772684879784524. This agreement is between two computational methods applied to the same model, not between independent physical experiments.
Recorded verification
The implementation asserts agreement between trace-norm and closed-form D, agreement between marginal-coherence and formula V, nonnegative joint-state eigenvalues within 10⁻¹² tolerance, and trace one. It also records Kraus trace preservation and D² + V² ≈ 0.8272.
Remaining boundary
The explicit channel resolves the missing physical construction from the preceding round. It does not establish the same D for a different accessible environment, mixed markers, population-changing noise, or losses with selective detection. Those were retained as next questions rather than silently treated as solved.
Round 6: why the same visibility can accompany different D
Reason for the change
Round 6 returned to equal priors to isolate coherence loss from the additional predictability supplied by unequal path populations. It was not a replacement of the unequal-prior result.
Inputs and results
The marker overlap remained γ = 0.6. The path probabilities became 0.5 and 0.5, while the channel parameter became η = 0.4.
Before dephasing:
D = 0.8, V = 0.6, D² + V² = 1.
After dephasing:
D = 0.8, V = 0.24, D² + V² = 0.6976.
The stored joint-state eigenvalues after dephasing are approximately 0, 0, 0.3, and 0.7. Tiny values of order 10⁻¹⁷ around zero are numerical rounding, not evidence of a negative physical eigenvalue. The Kraus trace-preservation check is true.
Why comparison across rounds matters
Rounds 4–5 and Round 6 both have V = 0.24, but their states are different:
- Rounds 4–5: p = 0.8, η = 0.5, D ≈ 0.8773.
- Round 6: p = 0.5, η = 0.4, D = 0.8.
Visibility alone cannot identify the prior probabilities, the marker discrimination task, or the amount of phase noise. The archived assertions verify the before/after contrast and both sums to a tolerance of 10⁻¹².
Question carried forward
The next target was to compare operational definitions, marker accessibility, and mixed-state models against actual measurement procedures. The preserved seventh-round work pursued two theoretical subproblems of this target. It did not complete a fit to real detector data.
Round 7A: complementary eraser outcomes without a changed marginal
The archived result
This branch used orthogonal which-path markers, a four-by-four joint state, a legal dephasing channel, and a marker measurement. Its standalone research card reports a grid of three path weights, three dephasing values, and 257 phases: 3 × 3 × 257 = 2,313 numerical checks. The recorded conclusion is that the two marker-outcome joint contributions can carry opposite fringes while their sum remains 1/2.
The complete probability-table artifact cited by that card was not recovered for this reconstruction. The exact nine parameter combinations, row-level residuals, and original implementation are therefore not presented as inspected here. The equations below are an explicit explanatory reconstruction of the stated orthogonal-marker model, not a claim to have recovered that missing table or rerun its 2,313 checks.
State, measurements, and dephasing
Take
|Ψ⟩ = √p |0⟩|0⟩ + √q |1⟩|1⟩.
In the same ordered basis as before, pure path dephasing gives
ρ = [[p, 0, 0, η√pq], [0, 0, 0, 0], [0, 0, 0, 0], [η√pq, 0, 0, q]].
Measure the marker in the eraser basis |+⟩ = (|0⟩ + |1⟩)/√2 and |−⟩ = (|0⟩ − |1⟩)/√2. At the path output, use the balanced phase-dependent projection |+φ⟩ = (|0⟩ + e^{iφ}|1⟩)/√2.
The joint contributions for that output and the two marker outcomes are
J₊(φ) = P(+φ, marker +) = 1/4 + (η√pq/2) cos φ,
J₋(φ) = P(+φ, marker −) = 1/4 − (η√pq/2) cos φ.
They sum to 1/2 for every φ. Each is a joint probability, still weighted by how often its marker group occurs.
The normalization that must not be skipped
Each marker outcome has probability 1/2. Therefore the normalized probabilities within each selected marker group are
P(+φ | marker +) = 1/2 + η√pq cos φ,
P(+φ | marker −) = 1/2 − η√pq cos φ.
These conditional curves each have visibility 2η√pq. They sum to 1, but that unweighted sum is not the marginal probability at the output. The output marginal is the weighted sum:
(1/2)P(+φ | marker +) + (1/2)P(+φ | marker −) = 1/2.
Consequently a chart must say whether it displays J₊ and J₋ or the normalized conditional curves. Calling a 1/4-baseline joint contribution a conditional probability creates a factor-of-two error.
What the fringes mean
When p = q = 1/2 and η = 1, the two conditional curves are (1 ± cos φ)/2: full-contrast fringes with opposite phase. Unequal paths limit contrast through 2√pq. Complete phase dephasing, η = 0, removes both fringes. These are direct consequences of the displayed model, not additional archived trials.
The unconditional path density matrix is diag(p, q). Its balanced phase-output probability is 1/2. Sorting by a correlated marker outcome reveals structure in selected data; it does not change the already recorded unsorted distribution. A local marker operation with all outcomes retained cannot be used to communicate into the past. The number 1/2 refers to this balanced output measurement, not to a claim that every real double-slit screen is spatially uniform.
Remaining question
The branch proposed studying how much contrast is recoverable when only part of the marker information is accessible. Nonorthogonal markers and inaccessible environmental records require explicit new definitions and calculations.
Round 7B: a valid quantum filter exposes invalid ensemble mixing
Question and relation to the other branch
Can someone manufacture an apparent violation by taking the best distinguishability from one selected group and the best visibility from another?
This separately preserved Round 7 branch answers yes with an explicit legal two-outcome filter. Unlike the orthogonal-marker eraser branch, it starts with partially overlapping symmetric marker states and computes the normalized states after each filter outcome.
Symmetric markers
For 0 < c < 1, set
|d₀⟩ = (√((1 + c)/2), √((1 − c)/2))ᵀ,
|d₁⟩ = (√((1 + c)/2), −√((1 − c)/2))ᵀ.
Their overlap is c. With equal path priors, define
Ks = diag(√((1 − c)/(1 + c)), 1),
Kf = diag(√(2c/(1 + c)), 0).
The completeness identity is immediate:
Ks†Ks + Kf†Kf = diag((1 − c + 2c)/(1 + c), 1) = I.
The two outcomes together form a trace-preserving instrument. Each selected outcome alone is trace-decreasing; its probability and subsequent normalization must be retained.
Success branch
Applying Ks to either marker gives vectors proportional to (1, ±1). Their squared norms are both 1 − c. The normalized markers are orthogonal:
|ds,0⟩ = (1, 1)ᵀ/√2,
|ds,1⟩ = (1, −1)ᵀ/√2.
Because both paths have the same success probability, conditioning leaves their priors equal. The success ensemble has probability 1 − c, D = 1, V = 0, and D² + V² = 1.
Failure branch
Applying Kf gives the same vector (√c, 0)ᵀ from either input marker. Its probability is c. After normalization both markers are |0⟩. The failure ensemble therefore has D = 0, V = 1, and D² + V² = 1.
Here “failure” means failure to distinguish the path under the filter's discrimination task. It is precisely the branch whose identical markers permit full interference.
The false result and why it fails
Taking Ds from the success group and Vf from the failure group gives
Ds² + Vf² = 1 + 1 = 2.
No single ensemble has those two values. The expression mixes different populations and therefore does not test the duality relation. The error is in the statistic's construction, not a breakdown of the quantum model.
At c = 0.6 the success probability is 0.4 and the failure probability is 0.6. The code verifies equality of the branch probabilities for the two input paths before normalizing their marker vectors.
Complete numerical sweep recorded
The preserved program checks c = 0.1, 0.2, 0.3, 0.4, 0.5, 0.6, 0.7, 0.8, and 0.9. The success probabilities are respectively 0.9 down to 0.1; the failure probabilities are 0.1 up to 0.9.
At every value, the success branch gives D ≈ 1 and V ≈ 0; the failure branch gives D = 0 and V = 1. Both same-ensemble sums are approximately one, while the deliberately mixed statistic is approximately two. Deviations such as 1.0000000000000004 and residual overlaps near 10⁻¹⁶ reflect floating-point arithmetic. The implementation checks the sums against 10⁻¹² tolerance and checks Kraus completeness using numerical matrix comparison.
Nine finite cases support the implementation check. The general statement for 0 < c < 1 rests on the algebra above. At an endpoint one branch has zero probability, so its normalized conditional state cannot be treated as an observed ensemble; the original sweep avoids those endpoints.
The practical repair
Attach the same ensemble identity, path priors, and selection condition to any pair of D and V values before combining them. Also report selection probability, so a high-contrast rare branch is not presented as though it describes every detection.
The archived next step was to extend this accounting to unequal priors and derive conditions for postselection-induced apparent violations. The current result proves the equal-prior counterexample; it does not claim that extension was already completed.
What the seven rounds establish
The progression resolves several different errors, each with a specific repair:
- A pair of numbers satisfying an inequality is weaker than a state construction. Round 2 supplied normalized marker states.
- Lower visibility does not necessarily mean more information in the accessible marker. Round 3 supplied independent phase noise.
- Prior bias and optimal marker-assisted discrimination are different. Round 4 computed both.
- A reduced matrix does not exhibit the complete preparation and channel. Round 5 supplied the joint state and Kraus operators.
- Equal visibility does not imply equal quantum states or equal D. Round 6 isolated changes in priors and dephasing.
- Joint probability contributions are not normalized conditional probabilities. Round 7A requires explicit branch weights.
- Distinguishability from one selected ensemble cannot be combined with visibility from another. Round 7B supplied an explicit counterexample.
The strongest common conclusion is methodological and mathematical: report the state, accessible information, measurement, priors, and conditioning together. When these are held fixed, the recorded examples obey their duality relations. Changing one of them changes the question being answered.
Open research questions retained from the record
- Mixed marker states: replace pure-marker overlap formulas with trace-norm discrimination of the actual mixed states.
- Partial access: specify which marker or environmental degrees of freedom can be measured and calculate the recoverable contrast under that restriction.
- Population-changing channels: recompute priors and conditional markers instead of carrying over the pure-phase-noise formulas.
- Unequal-prior postselection: report updated priors, branch probabilities, and D/V for each common ensemble.
- Real measurements: relate the model to a specific detector procedure, loss model, count normalization, and estimation uncertainty. No real experimental dataset was fitted in these rounds.
- Reproducibility of the eraser branch: recover its detailed probability table and original parameter grid before claiming row-by-row verification of the archived 2,313-check result.
A natural usable component is a small analysis or teaching tool that distinguishes joint, conditional, and marginal curves and refuses cross-ensemble comparisons. Its useful scope is the calculation and its diagnostics; application to measured data requires the measurement definitions above.
Technical appendix A: a common formula explains Rounds 2–6
Tracing the marker out of the coherent state gives
ρP = [[p, √pq γ*], [√pq γ, q]].
For real γ and pure path dephasing this becomes
ρP′ = [[p, η√pq γ], [η√pq γ, q]].
The determinant is pq(1 − η²γ²), which is nonnegative for the stated parameter ranges. Together with unit trace and Hermiticity, this proves positivity of this two-by-two matrix. Its eigenvalues are
λ± = [1 ± √((p − q)² + 4η²pqγ²)]/2.
For pure markers, the weighted marker-difference matrix has trace p − q and determinant −pq(1 − γ²). Its eigenvalues have opposite signs except in degenerate cases, leading to
D = √((p − q)² + 4pq(1 − γ²)) = √(1 − 4pqγ²).
The complementarity sum follows by direct substitution:
D² + V² = 1 − 4pqγ² + 4pqγ²η².
This derivation makes the role of accessible marker information explicit. Additional environmental access can change the discrimination problem; the formula is not an assertion about every possible observer.
Technical appendix B: the result ledger
Round 1, assumed pair A: D = 0.6; V = 0.8; sum = 1.00. Scalar consistency check only.
Round 1, assumed pair B: D = 0.6; V = 0.9; sum = 1.17. Rejected within the stated model.
Round 2: p = 0.5; γ = 0.6; η = 1; D = 0.8; V = 0.6; sum = 1.00. Explicit pure joint state.
Round 3: p = 0.5; γ = 0.6; η = 0.5; D = 0.8; V = 0.3; sum = 0.73. Phase-noise formula and two scalar checks.
Round 4: p = 0.8; γ = 0.6; η = 0.5; D ≈ 0.877268488; V = 0.24; sum = 0.8272. Positive reduced matrix and four recorded checks.
Round 5: same parameters and results as Round 4. Full joint matrix, trace-preserving Kraus construction, partial trace, and trace-norm cross-check.
Round 6 before noise: p = 0.5; γ = 0.6; η = 1; D = 0.8; V = 0.6; sum = 1.00.
Round 6 after noise: p = 0.5; γ = 0.6; η = 0.4; D = 0.8; V = 0.24; sum = 0.6976. Full joint-state calculation.
Round 7A: orthogonal markers; archived 3 × 3 × 257 grid; two joint eraser contributions sum to 1/2. Exact grid and original row-level artifact remain unrecovered in this account.
Round 7B: nine overlaps c = 0.1 to 0.9; two normalized branches at each overlap; each same-branch sum = 1; deliberately mixed sum = 2. The two Round 7 branches have separate evidence scopes.
Technical appendix C: minimum checks for a faithful implementation
The archived computations and their explanatory reconstruction imply a concrete verification order:
- Check normalization and basis order of the input state.
- Check K†K completeness across all channel or instrument outcomes.
- Check Hermiticity, trace, and positive semidefiniteness of unconditional states.
- Take the partial trace over the correct subsystem.
- Define the detector projection before interpreting any phase curve.
- For selected outcomes, calculate the trace as the branch probability before normalizing.
- Compute D with the priors and accessible marker states of that same ensemble.
- Identify whether each plotted number is joint, conditional, or marginal.
- Sum joint contributions, or weight normalized conditionals, to recover the marginal.
- Reject a duality comparison when the two metrics refer to different selections or access assumptions.
This list is an explanation of how to preserve the calculations' meaning. It does not add new executed test counts to the archived record.
References retained in the research record
The original rounds pointed to the following public method references. This reconstruction uses the archived cards, code, and numerical outputs; it does not claim a new reading of these papers or import their laboratory results into the calculations above.
- Englert's duality relation, cited in Round 1: https://doi.org/10.1103/PhysRevLett.77.2154
- The path-marker and conditional-statistics reference retained in Round 2: https://doi.org/10.1103/PhysRevA.60.4285
- The contemporary duality source retained in Rounds 5–6: https://doi.org/10.1038/s41534-025-01160-4
- The quantum-eraser method reference retained in the standalone Round 7 branch: https://doi.org/10.1103/PhysRevA.25.2208